


Unitree Robotics
Unitree H2
Unitree H2
net
The Unitree H2 is a full-sized humanoid robot designed to operate in human-centric environments. Standing 182 cm tall and featuring an advanced mechanical design and intelligent control systems, it can move autonomously, perform natural movements, and execute complex tasks requiring mobility and interaction with its surroundings. Equipped with advanced perception systems, high-performance computing units, and state-of-the-art AI algorithms, the robot serves as an excellent platform for the development of autonomous robotic systems, AI research, and business deployments.
Share


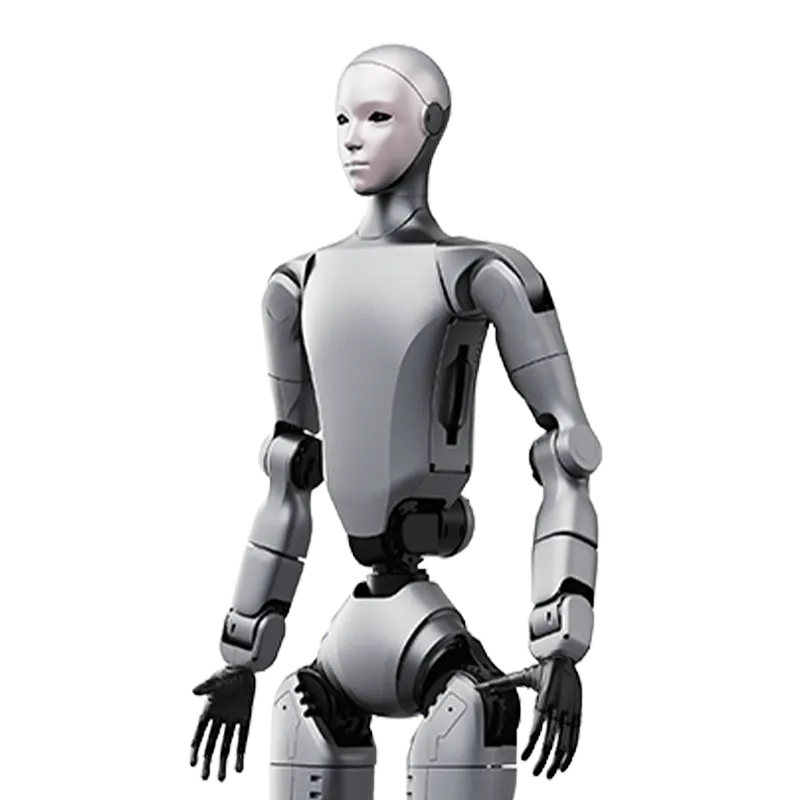

UNITREE H2
Open developer ecosystem
The Unitree H2 is an exceptionally developer-friendly platform. It provides extensive software support, including an open API and comprehensive SDKs, allowing for easy integration with modern simulators and seamless testing of proprietary artificial intelligence models.

UNITREE H2
Powerful powertrains
The robot is powered by proprietary, high-precision joint actuators with extremely high torque. They guarantee an excellent power-to-weight ratio, which allows the H2 to perform very fast, powerful movements while maintaining the lightweight nature of the entire structure.

UNITREE H2
Unrivaled dynamics and bipedal locomotion
Thanks to advanced algorithms based on reinforcement learning, the Unitree H2 demonstrates exceptional stability. The machine is not only capable of walking or running smoothly, but also of dynamically correcting its posture (e.g., after being bumped), confidently climbing stairs, and navigating over difficult and uneven terrain.
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 23 |
| Maximum knee torque | 90 N·m |
| Maximum arm load capacity | 2 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Unsupported |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 23 |
| Hand | Optionally, a dexterous hand and a 2-degree-of-freedom wrist |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 29 |
| Hand | Optionally, a dexterous hand and a 2-degree-of-freedom wrist |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| In-house software development | Fully supported at both low and high levels of programming |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 43 |
| Hands | Equipped with 2 three-fingered, dexterous Dex3-1 hands with force-controlled technology |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 43 |
| Hands | Equipped with two three-fingered, dexterous Dex3-1 hands featuring force-controlled technology and tactile sensors. |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 41 |
| Hands | Equipped with 2 five-fingered, dexterous Inspire hands (models RH56DFQ-2R for the right and RH56DFQ-2L for the left hand) |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 41 |
| Hands | The equipment includes 2 five-fingered, dexterous Inspire hands (models RH56DFTP-2R for the right hand and RH56DFTP-2L for the left hand). Each hand is equipped with 17 tactile sensors. |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 41 |
| Hands | Equipped with 2 powerful, five-fingered, dexterous Revo 2 Basic Edition hands |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 37 |
| Hands | Equipped with 2 three-fingered, dexterous Dex3-1 hands with force-controlled technology, without tactile sensors |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 37 |
| Hands | Equipped with two three-fingered, dexterous Dex3-1 hands featuring force-controlled technology and tactile sense. Each hand is equipped with as many as 33 tactile sensors. |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
| Technical specification | |
|---|---|
| Dimensions (standing position) | 1270 mm (H) x 450 mm (W) x 200 mm (D) |
| Dimensions (folded) | 690 mm (H) x 450 mm (W) x 300 mm (D) |
| Weight (with battery) | 35 kg |
| Length (calf + thigh) | 0.6 m |
| Arm span/reach | approx. 0.45 m |
| Internal cable routing (Full hollow internal alignment) | Yes (cables hidden in hollow shafts) |
| Cooling system | Local air cooling |
| Kinematics and Motion | |
| Total number of degrees of freedom (DOF) | 35 |
| Hands | Equipped with 2 powerful, five-fingered, dexterous Revo 2 Basic Edition (Revo 2 Basic) hands |
| Maximum knee torque | 120 N·m |
| Maximum arm load capacity | 3 kg |
| Joint range of motion (increased range of motion) | Lumbar spine Z-axis: ±155°, Knee joint: 0~165°, Hip joint: P (Pitch) ±154°, R (Roll) -30~+170°, Y (Yaw) ±158° |
| Joint encoder | Dual encoder |
| Battery and Power | |
| Power type | Battery in a 13S (13-series) configuration |
| Power supply equipment | 1x intelligent battery (quick-release), 1x charger |
| Working hours | approx. 2 hours |
| Image, Sound and Sensory | |
| Spatial sensors | Depth camera + 3D LiDAR |
| Sound | Stereo speakers and microphone array (standard) |
| Connectors, Communication and Computing | |
| Base plate (structural) | High-performance 8-core processor (CPU) |
| Additional computing unit (AI) | Built-in 100 TOPS module for software development using AI algorithms |
| Communication | Wi-Fi 6, Bluetooth 5.2 |
| Software and Control | |
| Gamepad | In the set |
| Over-the-air (OTA) updates | Supported |
| In-house software development | Fully supported at both low and high levels of programming |
| Developer support | Excellent technical support, complete developer documentation (manuals), and full ecosystem support provided. |
Contact form
Related products
-
Robot Booster T2 Pro
Regular price From €36.305,48Regular priceUnit price / per -
Agibot A2 Series
Regular price From €44.900,00Regular priceUnit price / per


